// ABOUT
I'm Jayasim. I build things and learn in public. This lab is me teaching myself modern robotics by reproducing systems at the edge of the field, one demo at a time.
I've spent years teaching AI through courses, workshops, and YouTube. The next frontier isn't just language models. It's embodied AI: robots that can see, move, and act in the physical world.
This lab is a 26-week, sim-first path: MuJoCo → Isaac factory → sysid → imitation → edge → rover → collector → menagerie → legs → VLA. Every week I log what shipped, what broke, and what I learned, including the failures.
If you're working on humanoids or embodied AI, I'd love to compare notes.
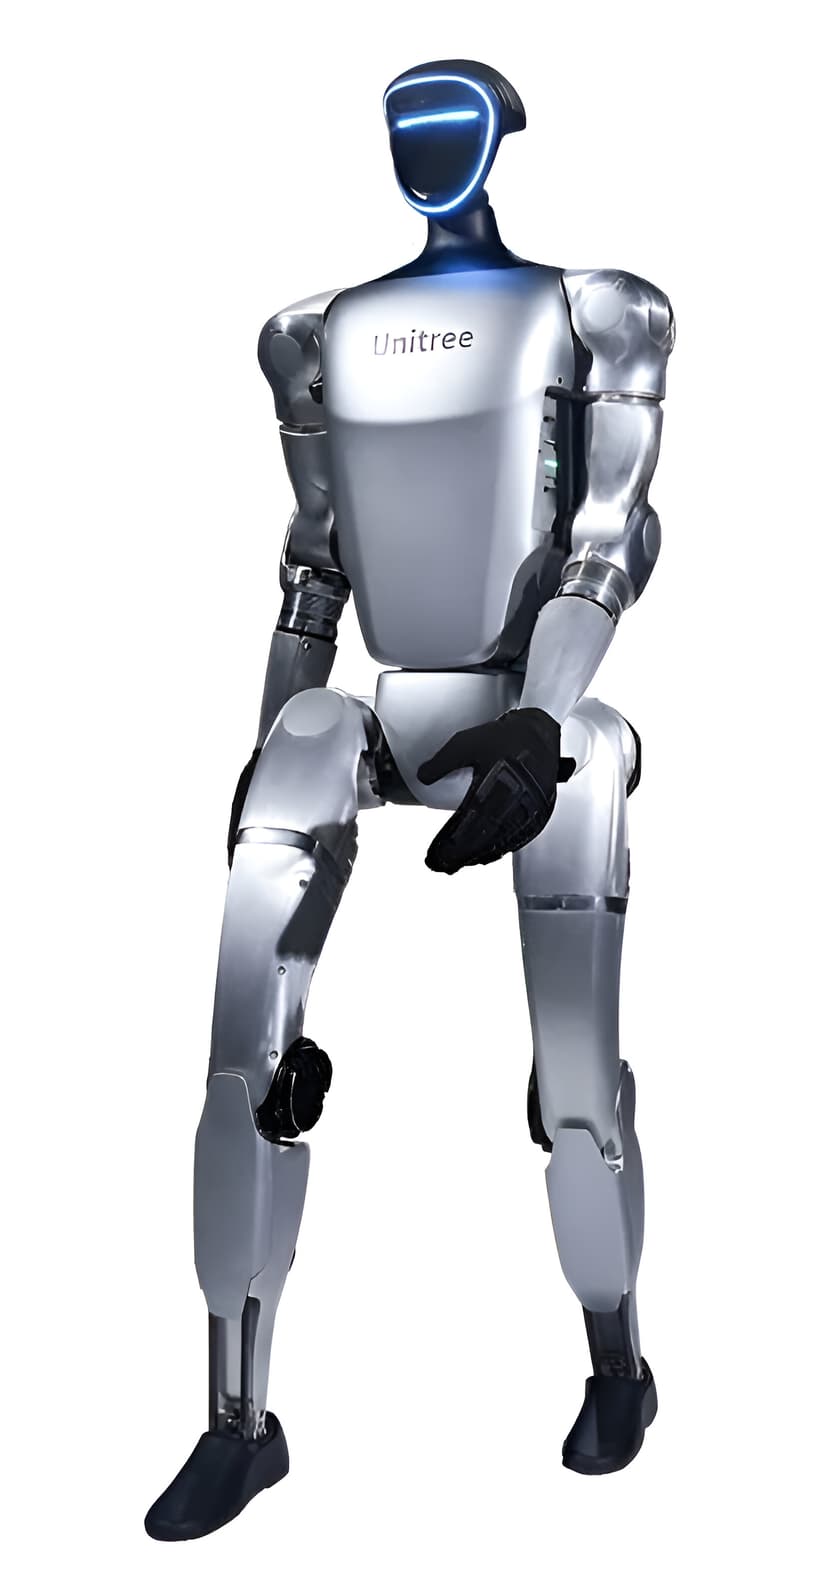 The Unitree G1, the humanoid in my simulation stack.