System ID on the arm
My first sim-to-real project. Run the same motion in MuJoCo and on the real SO-ARM101, then tune the simulator until it matches the arm on held-out trajectories.
Weeks 3–5 · SO-ARM101 you own · $0 · 03_sysid_arm/
Goal
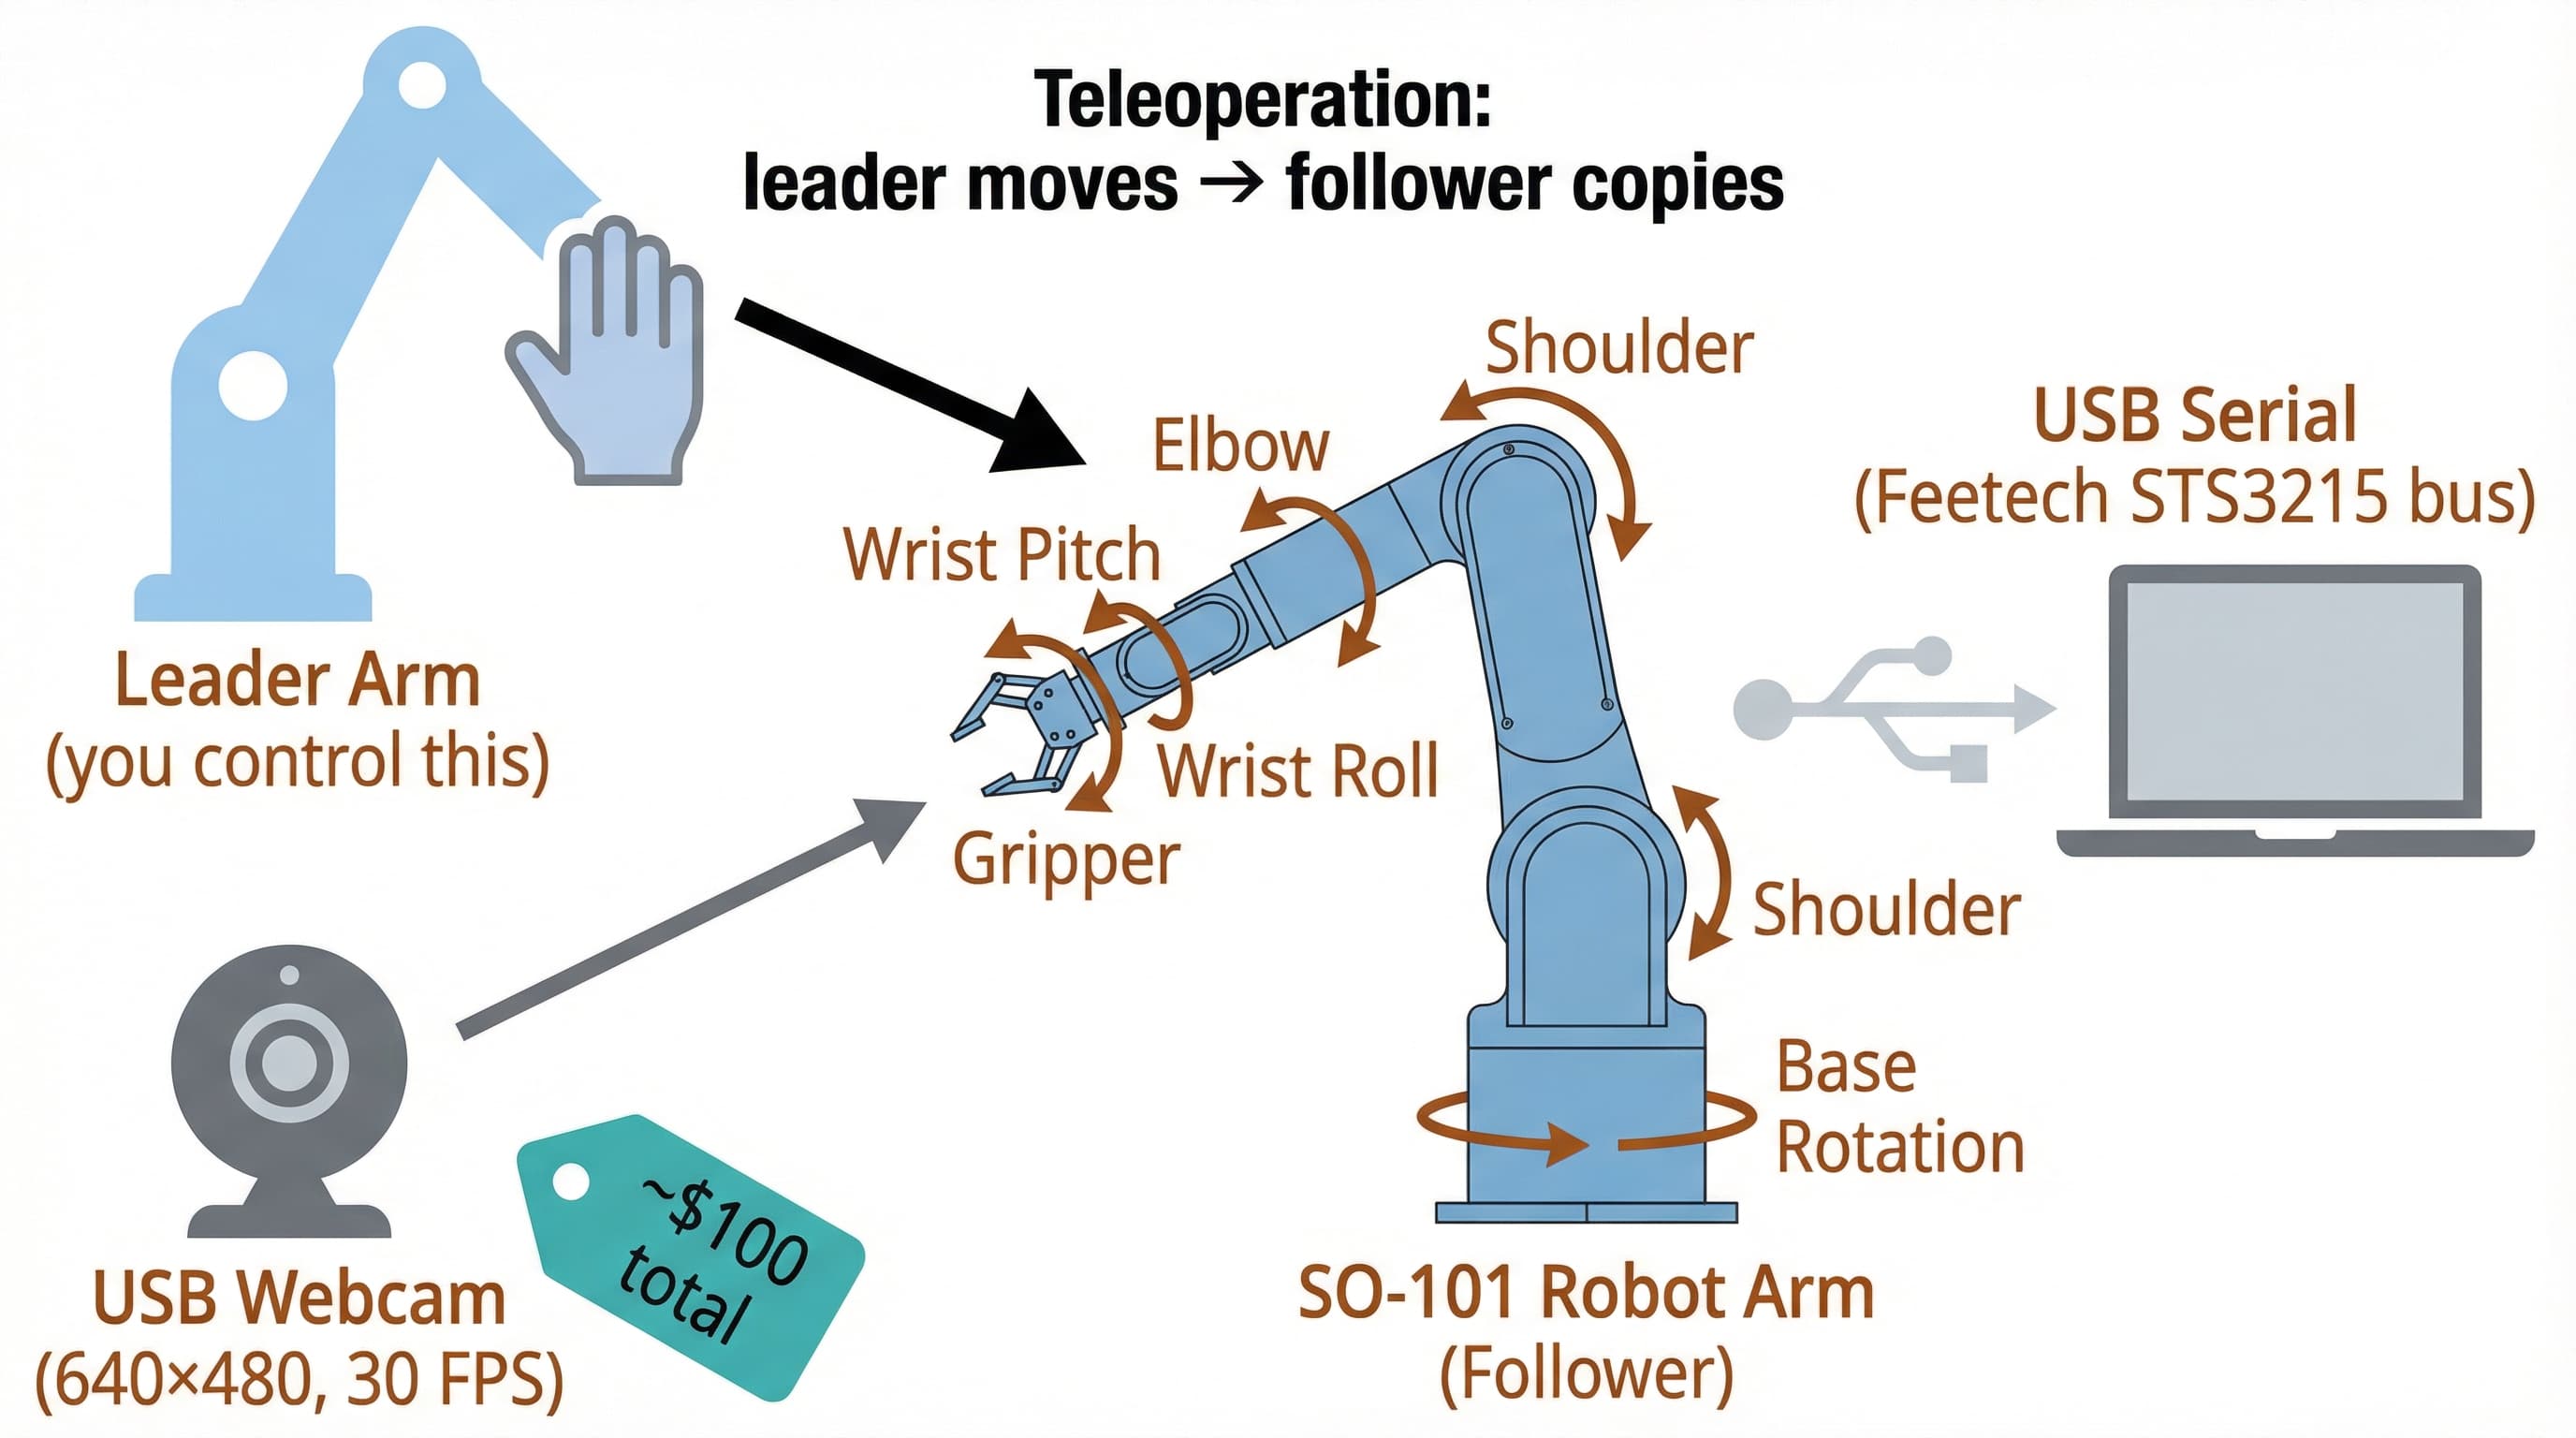
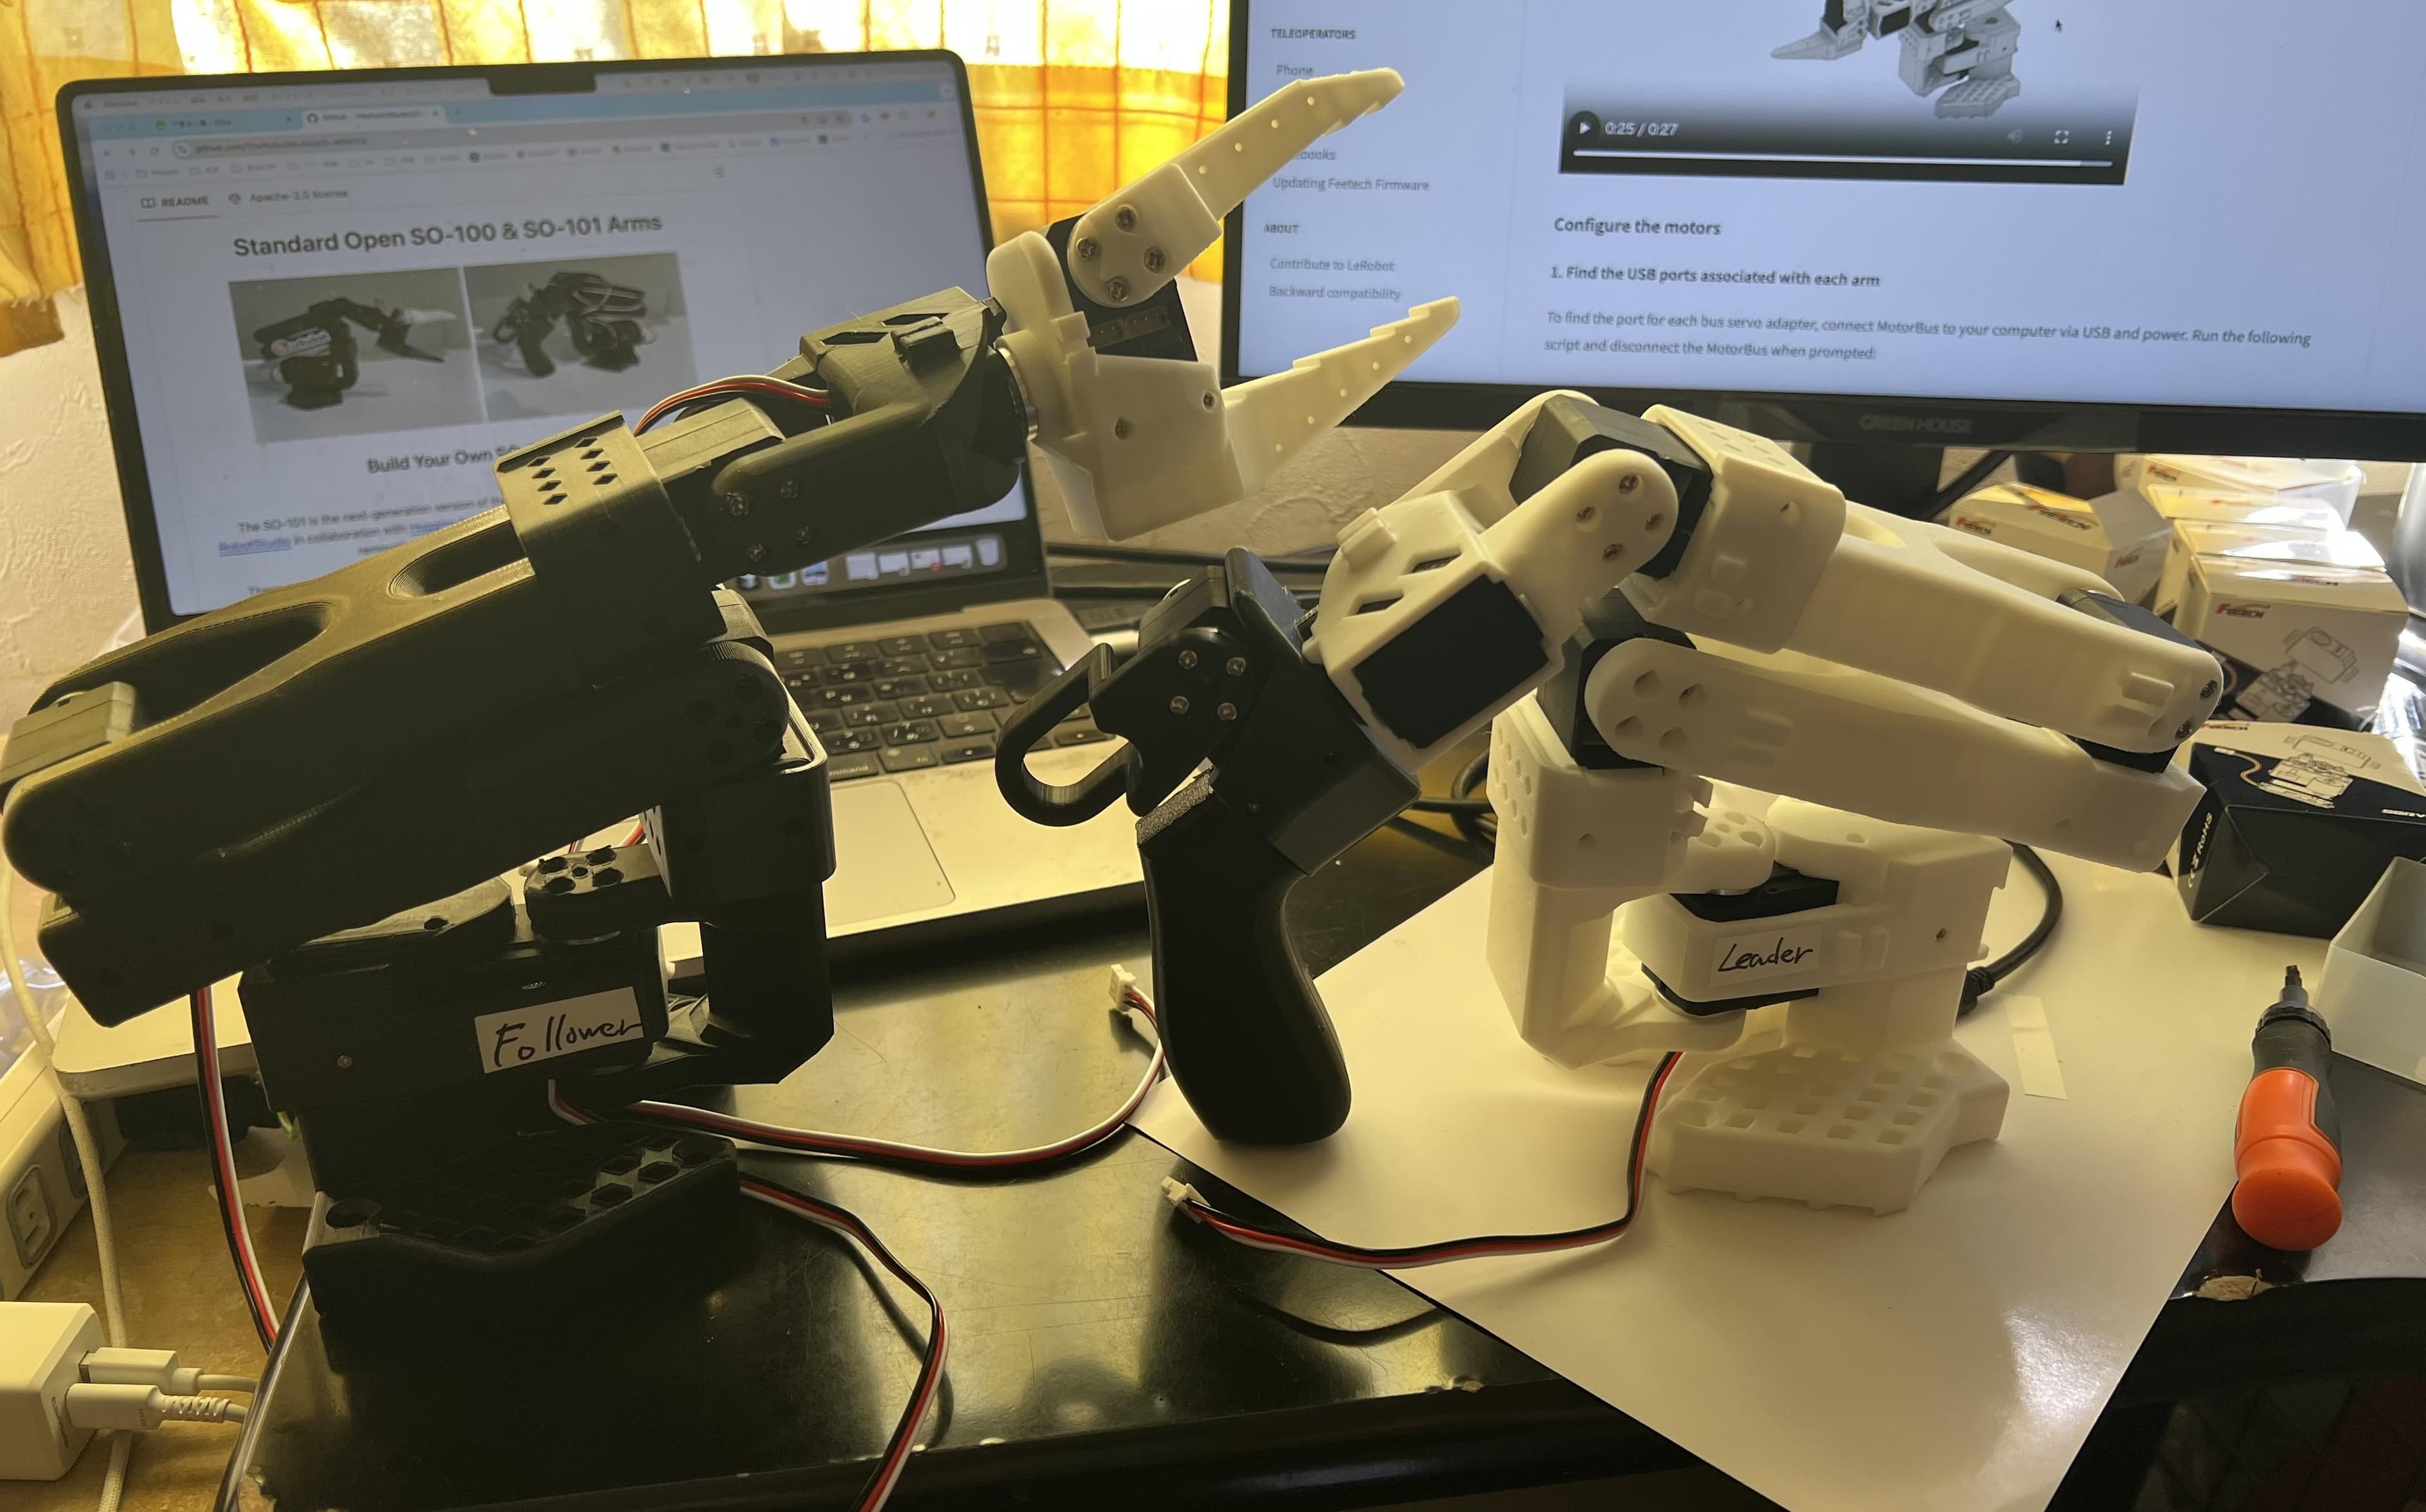
Every later project assumes the simulator looks like the machine. This is the check. Verify LeRobot’s SO-ARM101 MJCF against the physical arm (joint limits, axis directions). Build a trajectory set: per-joint steps, sinusoids at 0.25 / 0.5 / 1 / 2 Hz, then a multi-joint reach. Split fit vs held-out before you start. Run identical commands in MuJoCo and on the real arm. Measure per-joint RMS, phase lag, steady-state offset, overshoot. The overlay plots are the project. Fit friction, damping, armature/rotor inertia, and effective PD gains. The STS3215 servos run internal control you never see. Modelling them as ideal torque sources is the largest error.
Why it matters
This is the first time the simulator is tuned against real hardware. Every later hardware project depends on closing this gap. You do not trust simulators. You measure how much they lie, then shrink the gap. Project 6’s cloud-authored sim-to-real skill loop is the grown-up version of what this project teaches by hand. common/sysid/ is written once here and reused in P6, P8, and P9. No ROS 2. You need honest timing. A middleware hop corrupts the measurement you are taking.
The work
- 01
MJCF for the SO-ARM101. Verify joint limits and axis directions against the physical arm.
- 02
Trajectory set: per-joint steps, sinusoids at 0.25 / 0.5 / 1 / 2 Hz, multi-joint reach. Fit vs held-out split first.
- 03
Run in MuJoCo. Run the identical commands on the real arm at the same rate. Log as a paired run.
- 04
Measure per-joint RMS, phase lag, offset, overshoot. Overlay sim and real.
- 05
Fit friction, damping, armature, effective PD gains. Write docs/gap_reports/GR01-arm-sysid.md.
Done looks like
- A calibrated so_arm101.xml in common/sysid/models/.
- Overlay plots (sim vs real) for every joint, before and after identification.
- Numbers table: per-joint RMS error before → after, on held-out trajectories.
- Parameter table: each fitted value and the physical effect it stands in for.
- common/sysid/ reusable: trajectory generator, paired logger, gap-report generator.
- docs/gap_reports/GR01-arm-sysid.md
Stack card
| Simulator | MuJoCo 3.x |
|---|---|
| Trains on | n/a (not a training project) |
| Runs on | SO-ARM101 via USB serial |
| Buy | $0 |
| ROS 2 | No |
| Gazebo | No |
| Compute / target | None. Direct serial. Middleware corrupts the measurement. |
| Install | mujoco, lerobot (SO-101 description + servo driver), feetech-servo-sdk, scipy, pandas |
Repos to study
Watch out
- No ROS 2. Direct serial. A middleware hop corrupts the measurement.
- STS3215 internal control is invisible. Do not model the servos as ideal torque sources.
Workstreams
MJCF verification, trajectory generator, real-arm logging, parameter fit.
Held-out split, overlay plots, RMS table, GR01, reusable common/sysid/.
Cross-check. Eval stream can regenerate GR01 from the committed logs without re-fitting.
What this proves
You don't trust simulators, you quantify how much they lie, and you reduce it.
You don't trust simulators. You quantify how much they lie, and you reduce it.
Study videos
Gear / BOM